Current-based proprioception · Small-scale locomotion
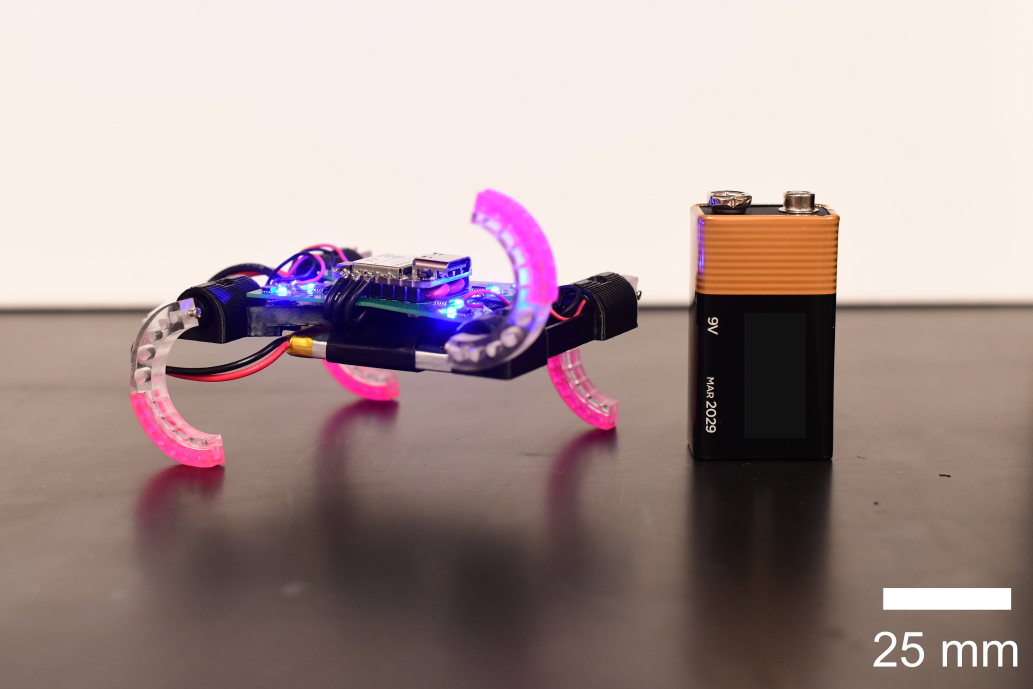
Little Quadruped Robot
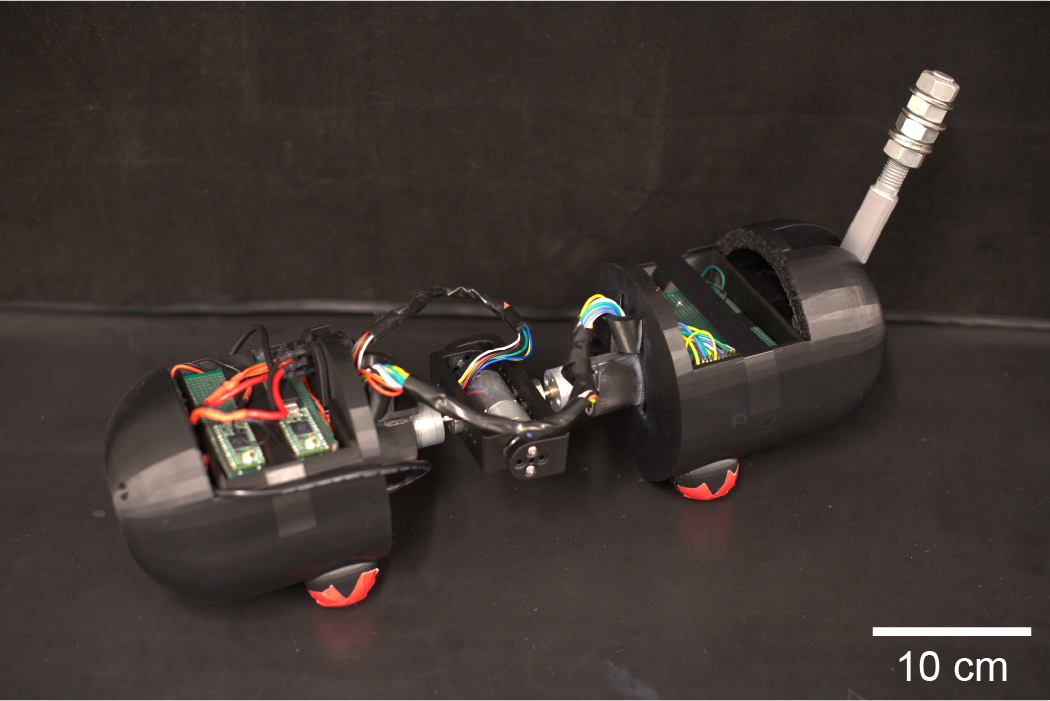
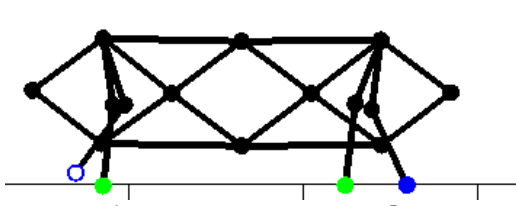
A fully untethered centimeter-scale quadruped that uses motor current as a source of proprioceptive leg feedback. A neural-network classifier estimates stance and swing, providing contact events for closed-loop gait coordination without joint encoders or dedicated foot-contact sensors.